Xiyan Huang

I am Xiyan Huang, a Master's graduate in Computer Science from ShanghaiTech University, where I was a member of the ShanghaiTech Automation and Robotics (STAR) Center, advised by Prof. Chenxi Xiao. My research interest lies in tactile-driven dexterous hand manipulation, aspiring to enable robots to interact with the world as adeptly as humans and achieve self-evolution.

即将加入 上海智元机器人(AGI BOT)

Email: origami@shanghaitech.edu.cn
Xiyan Huang
Placeholder

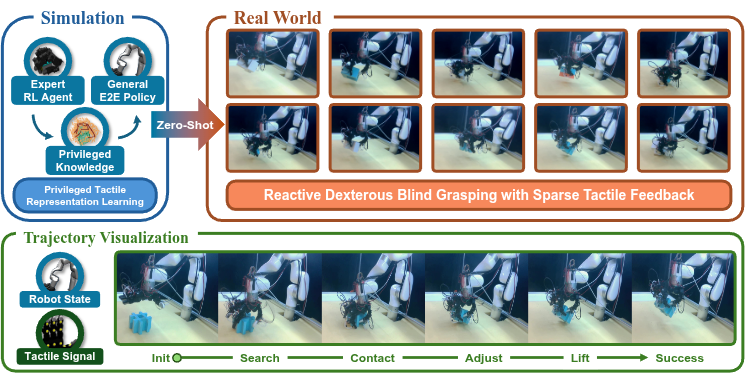
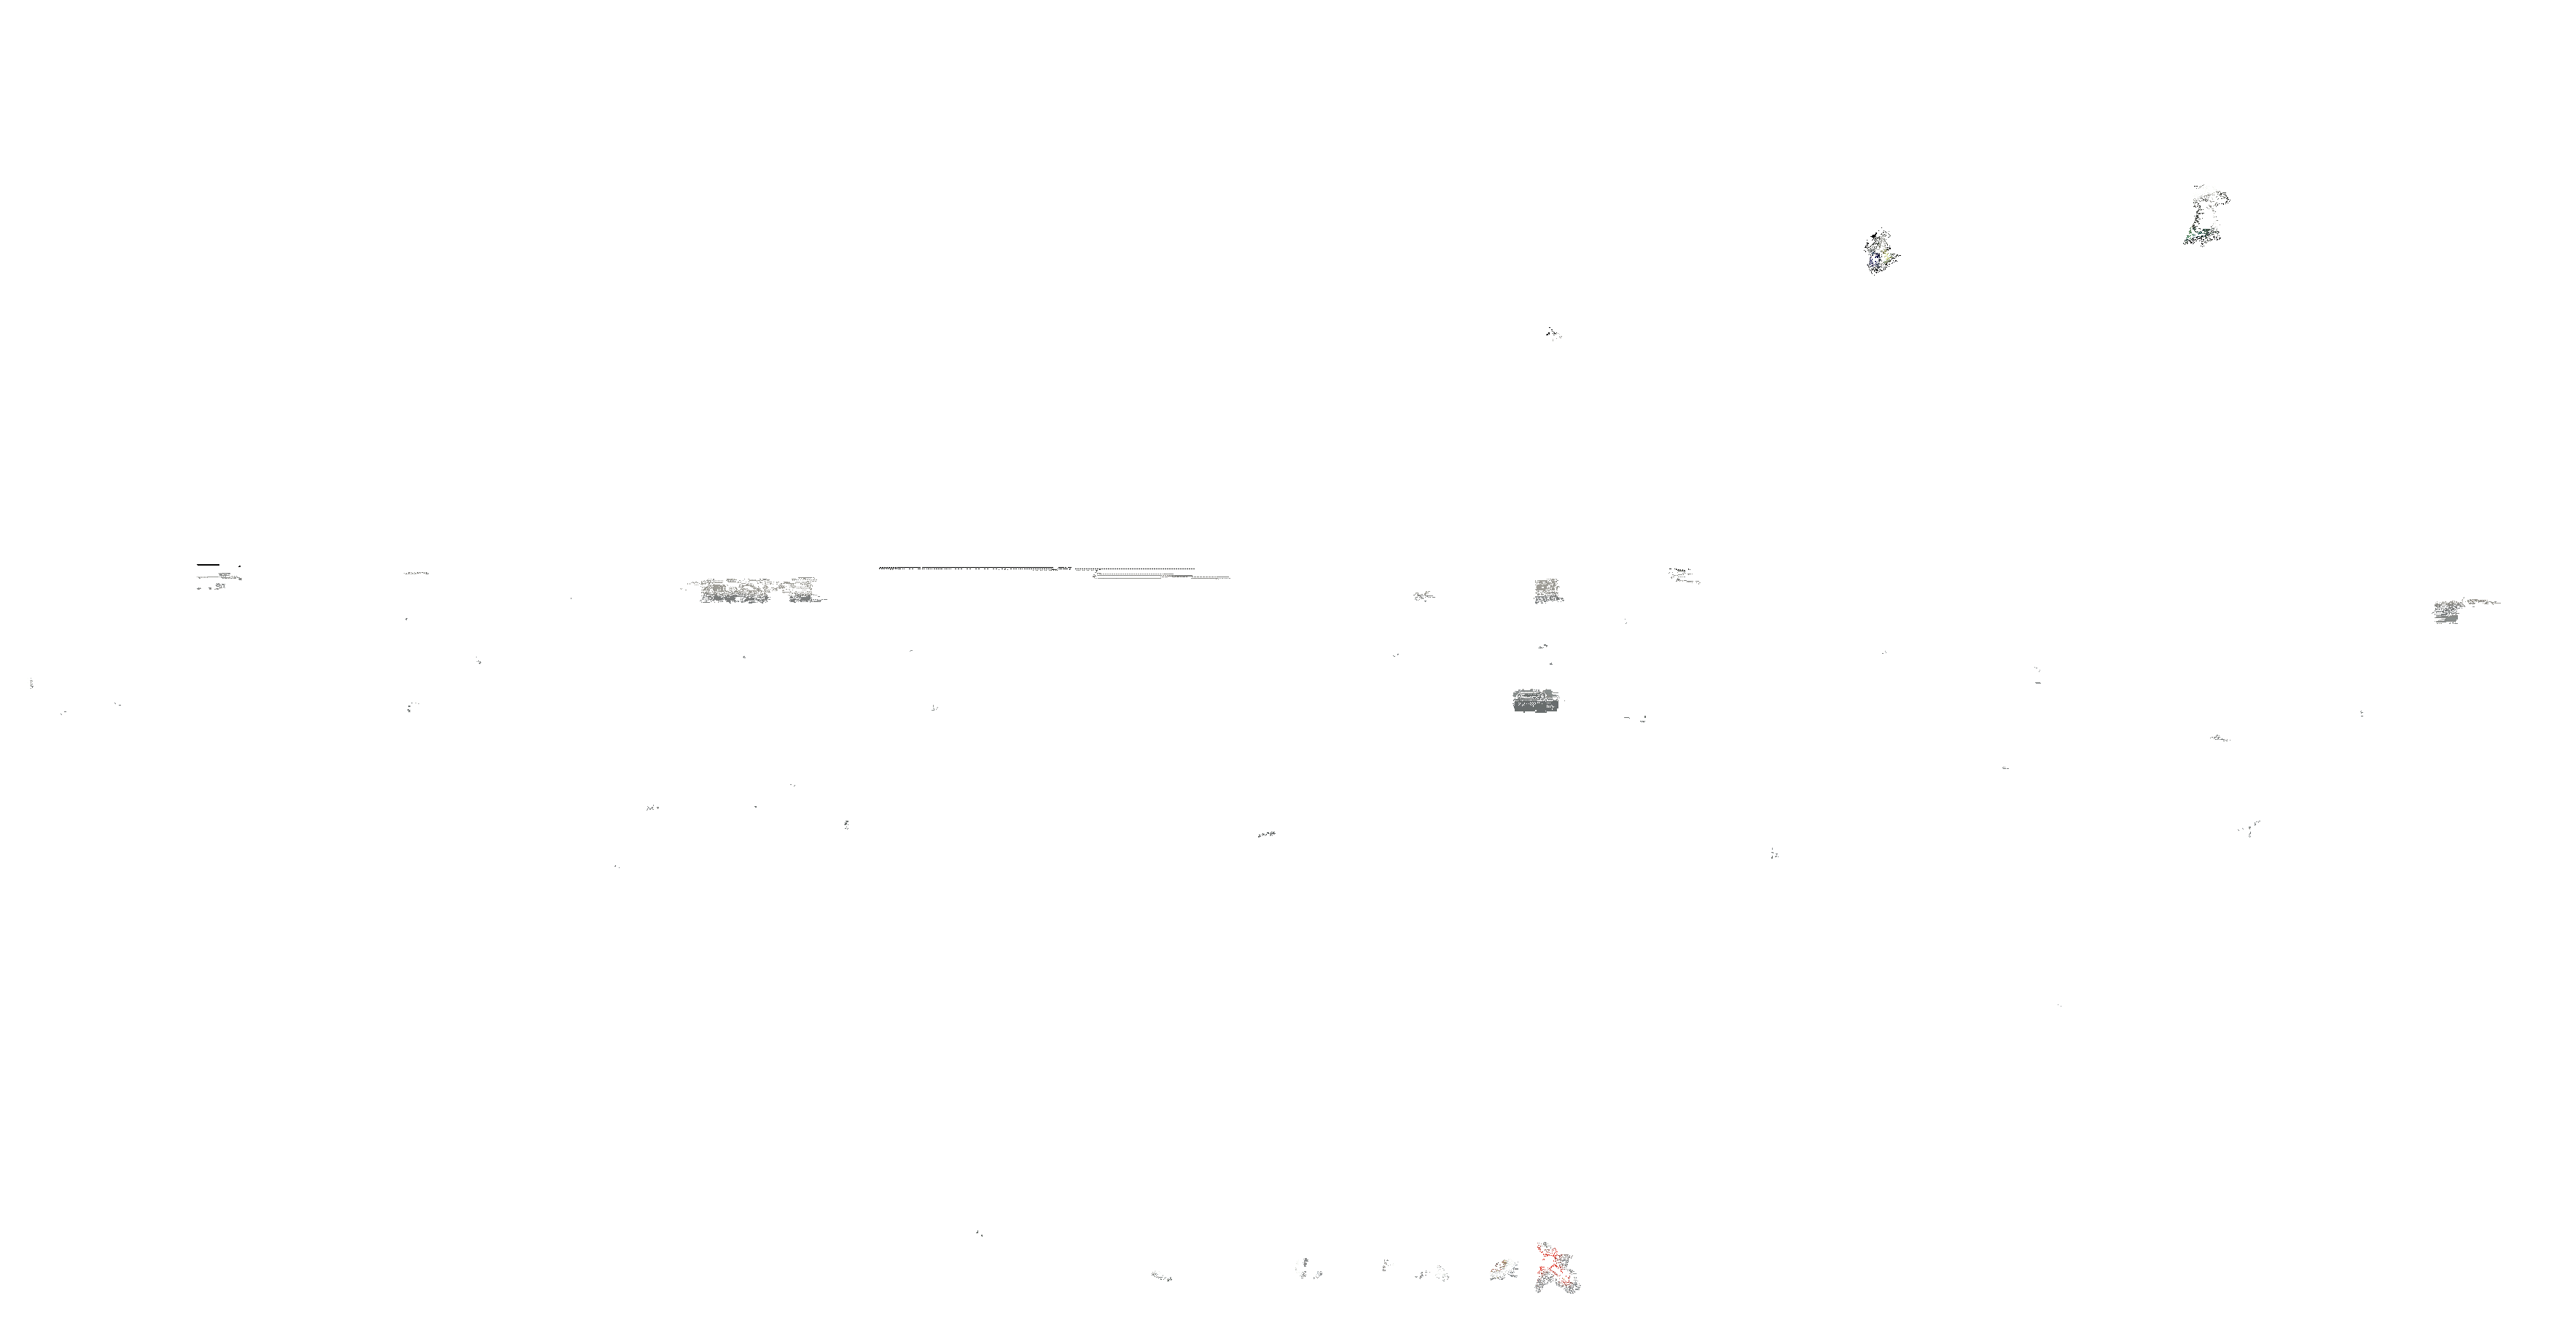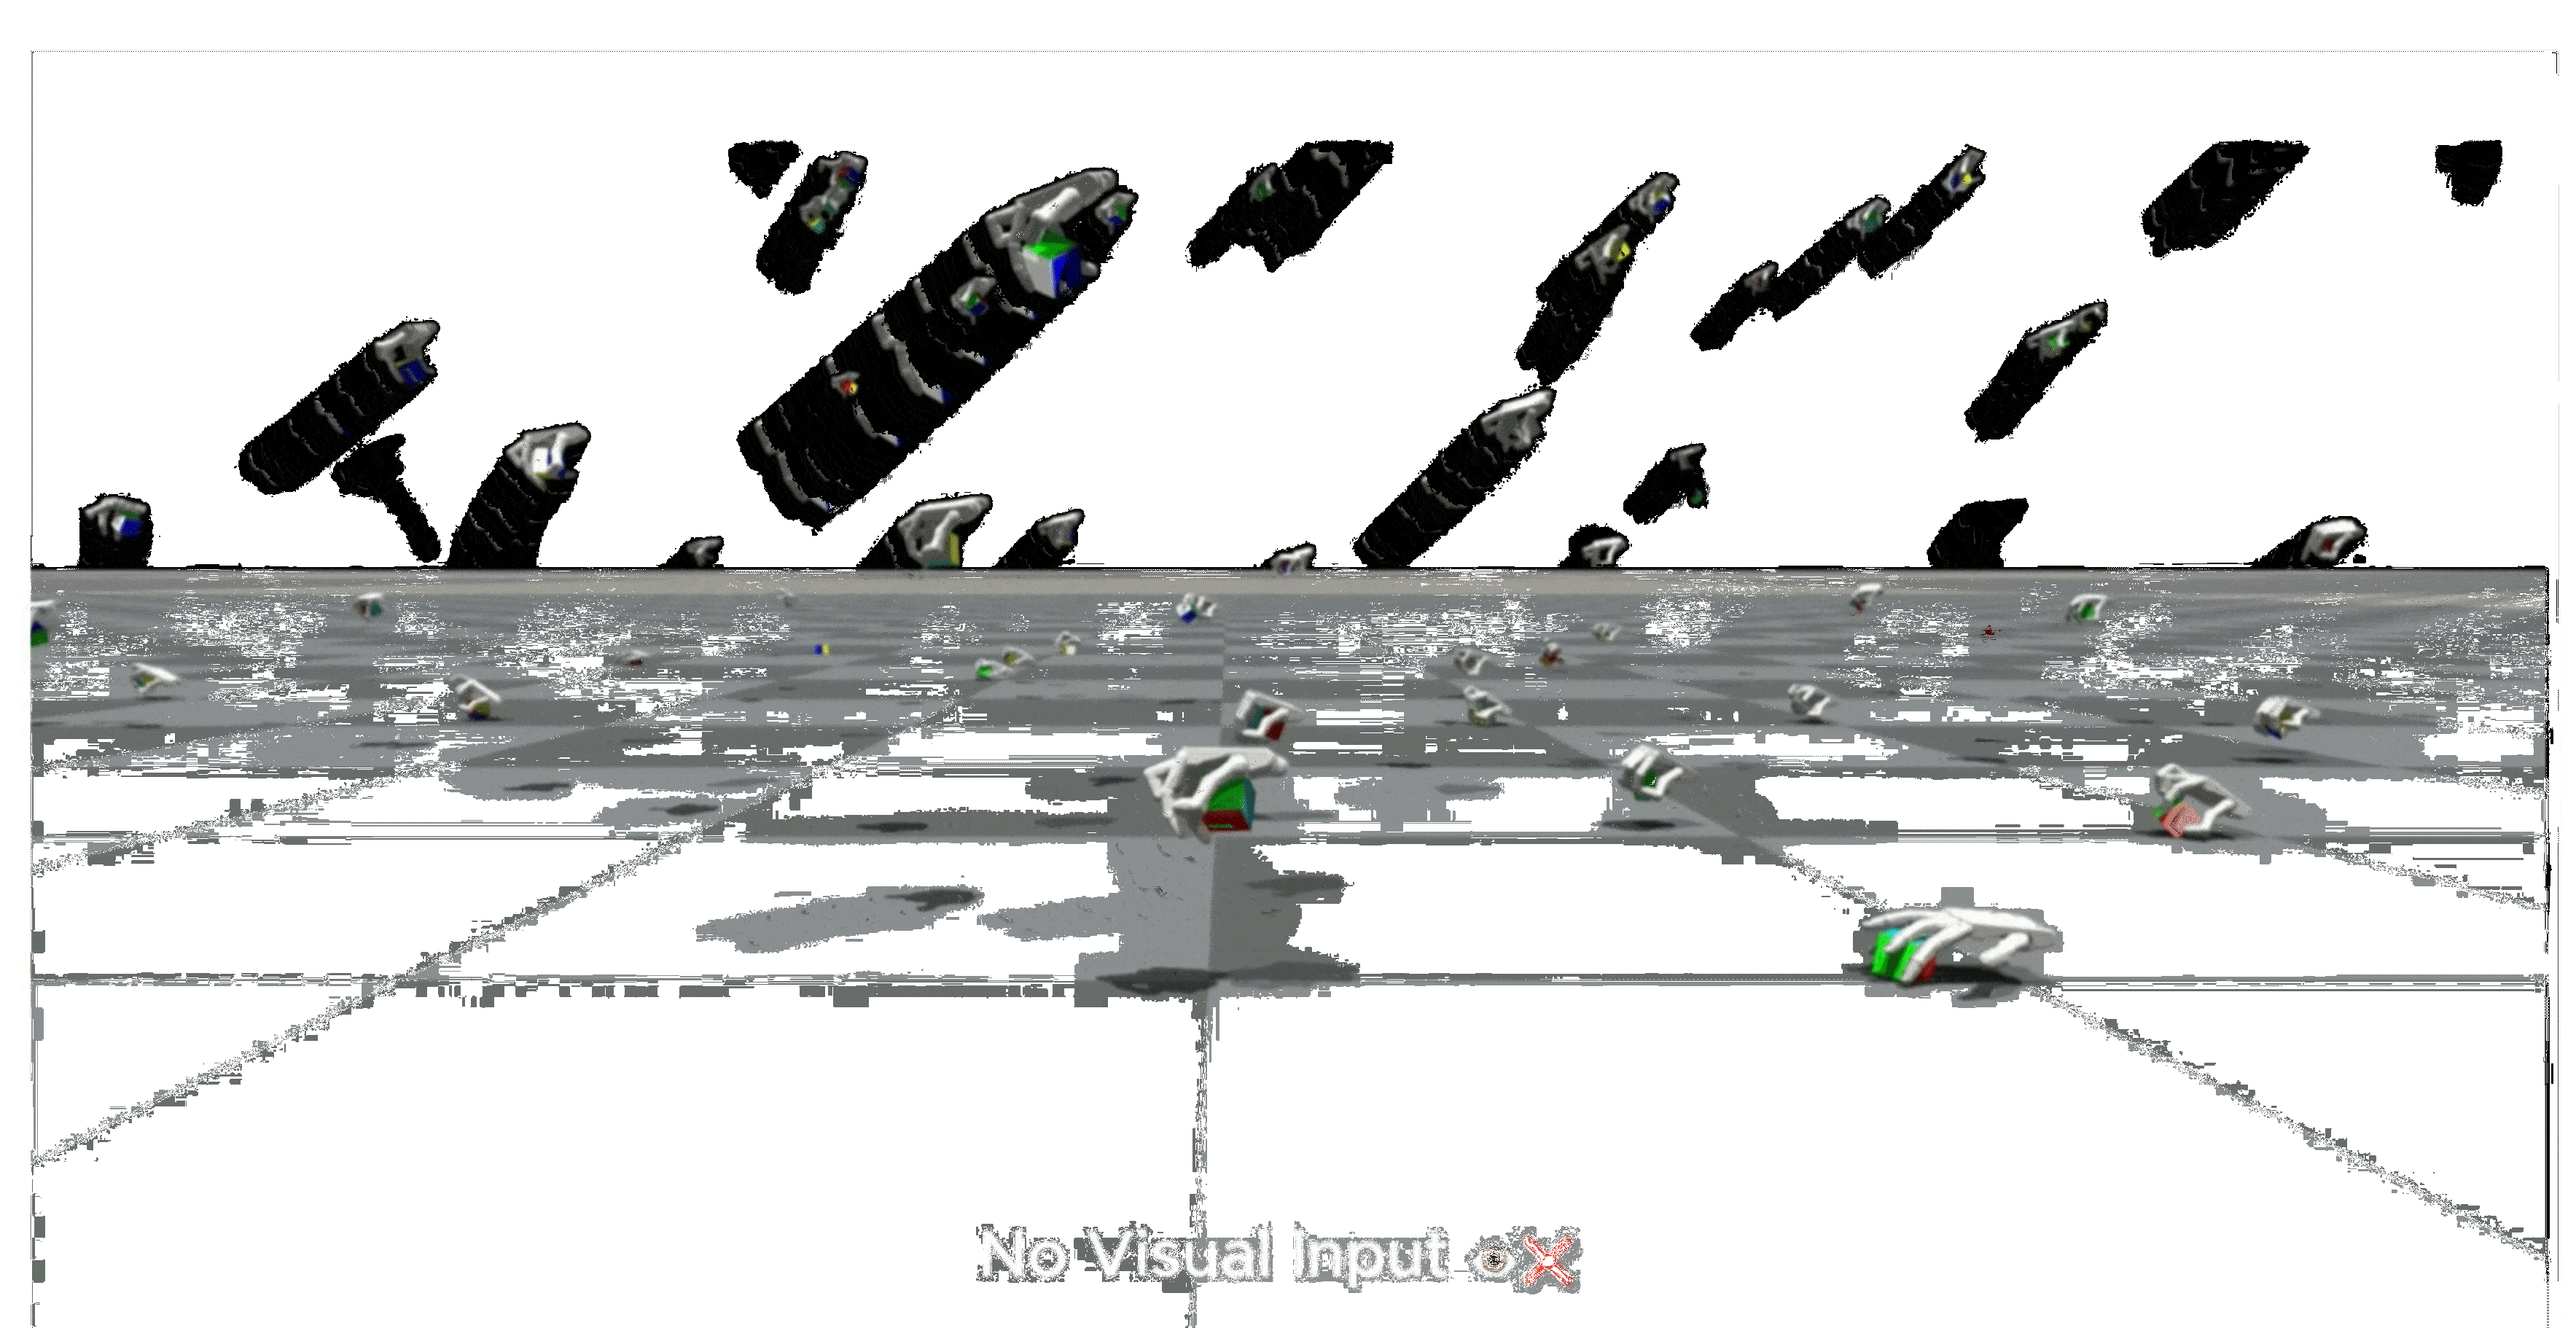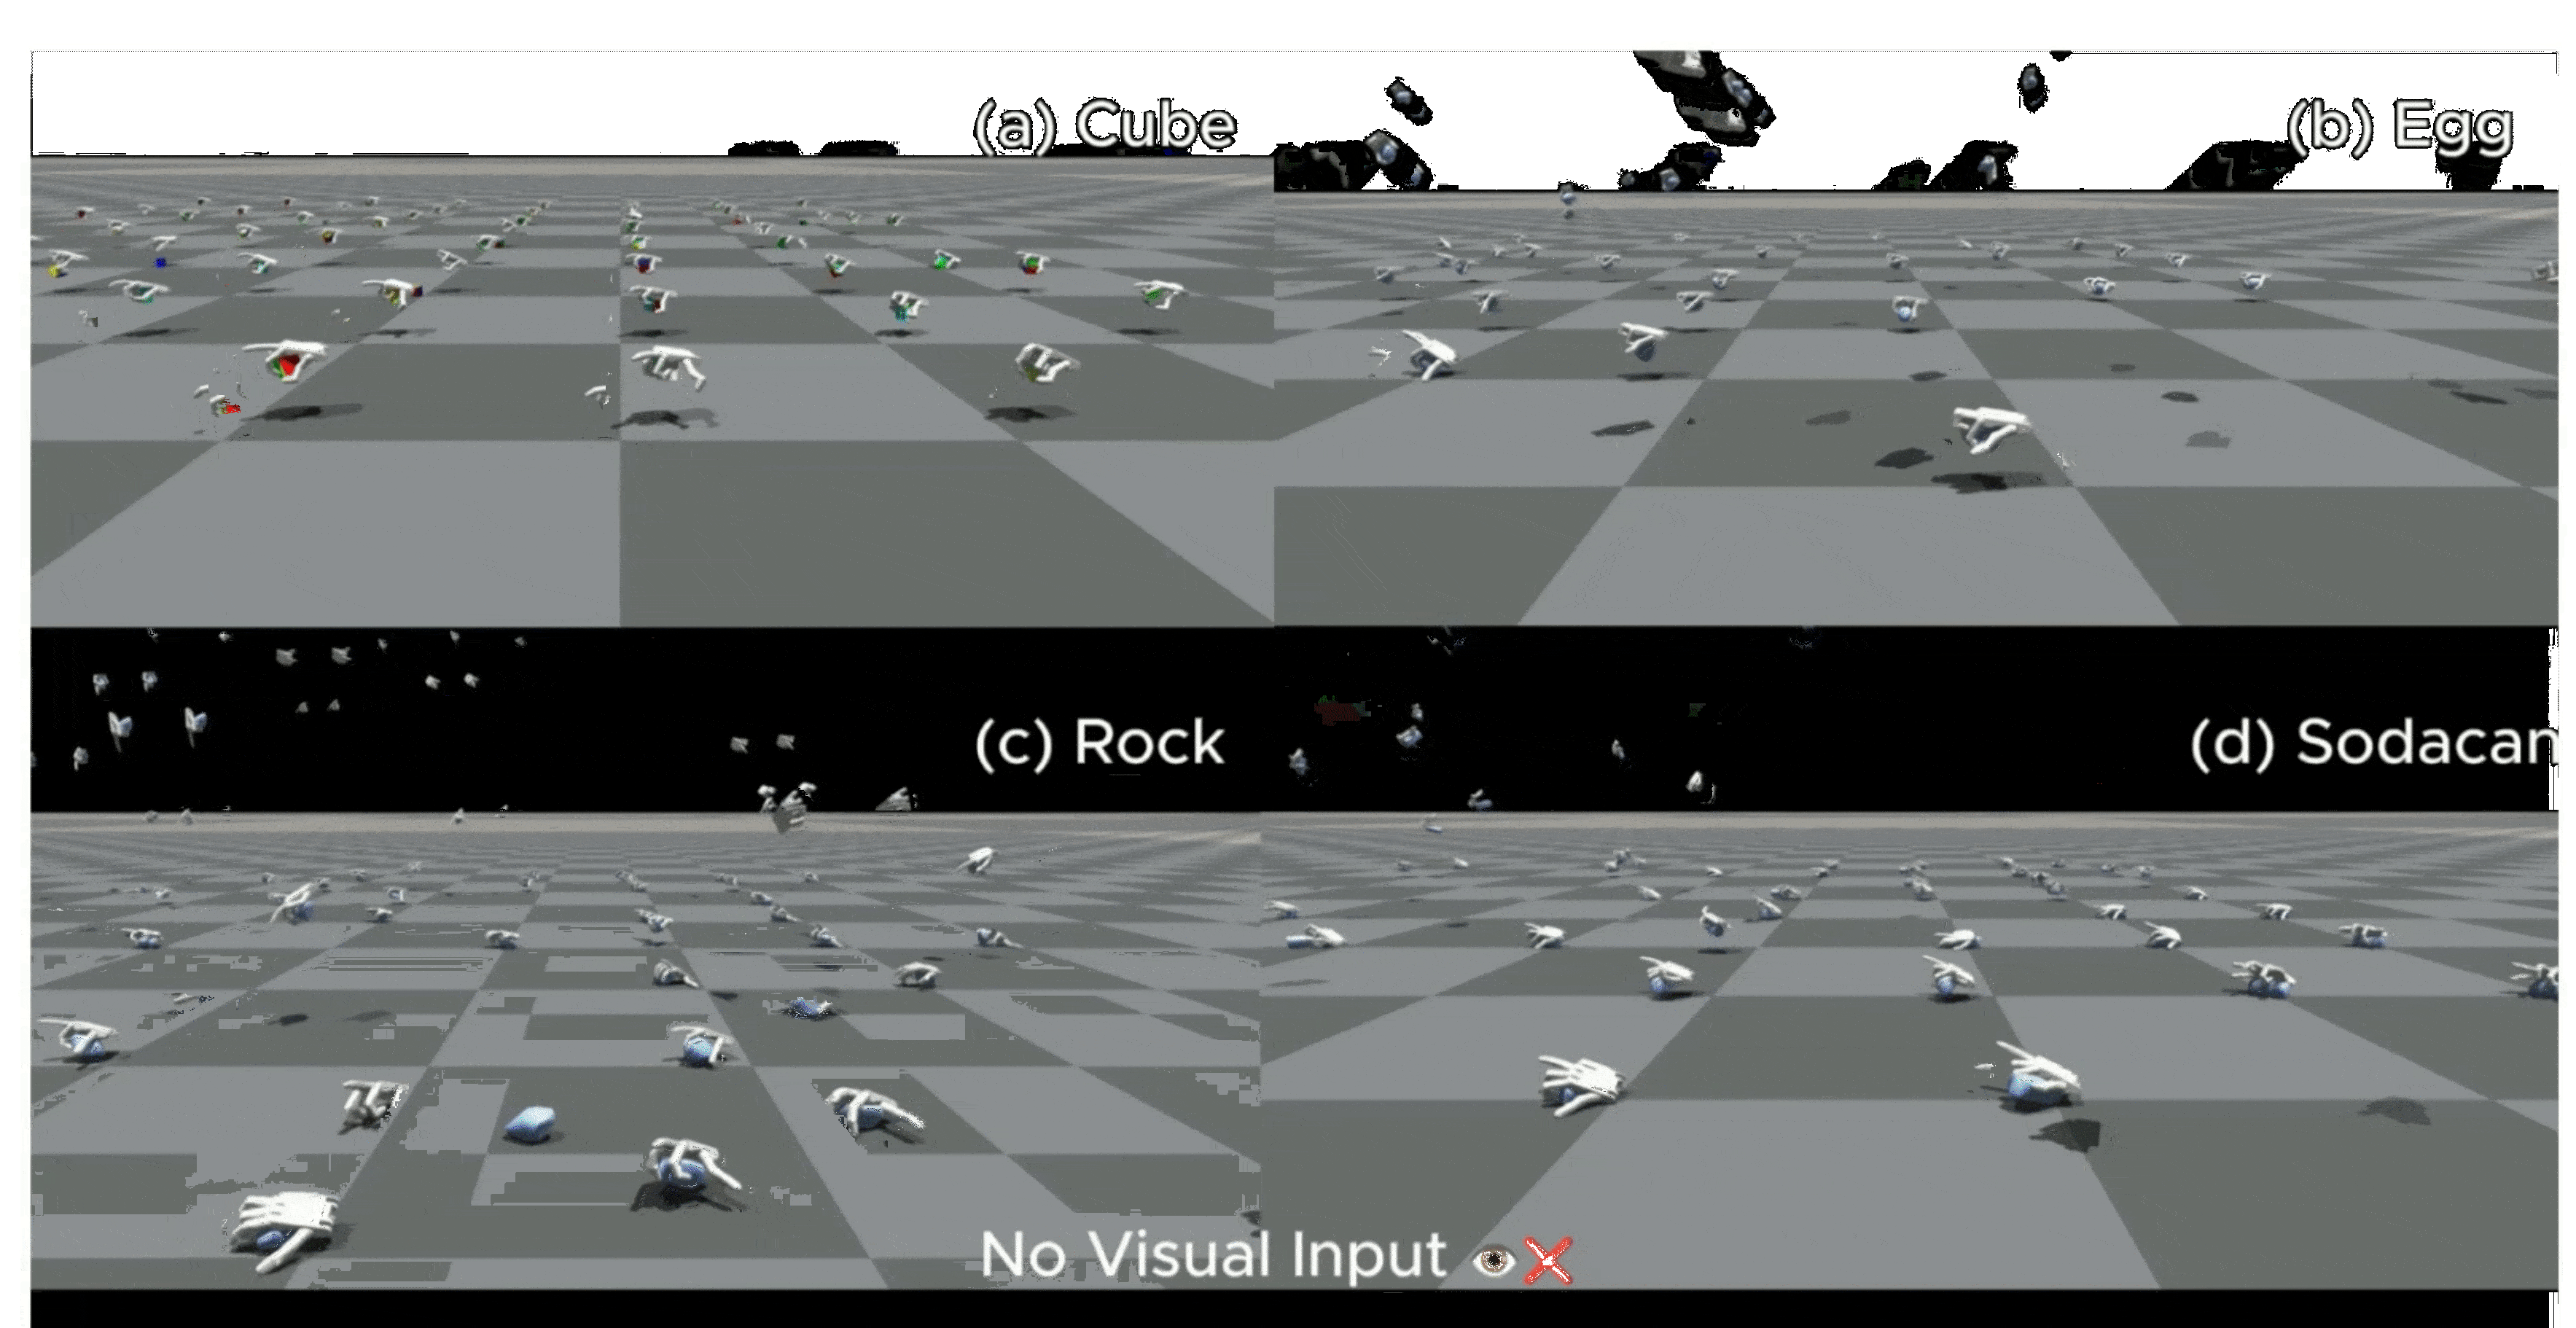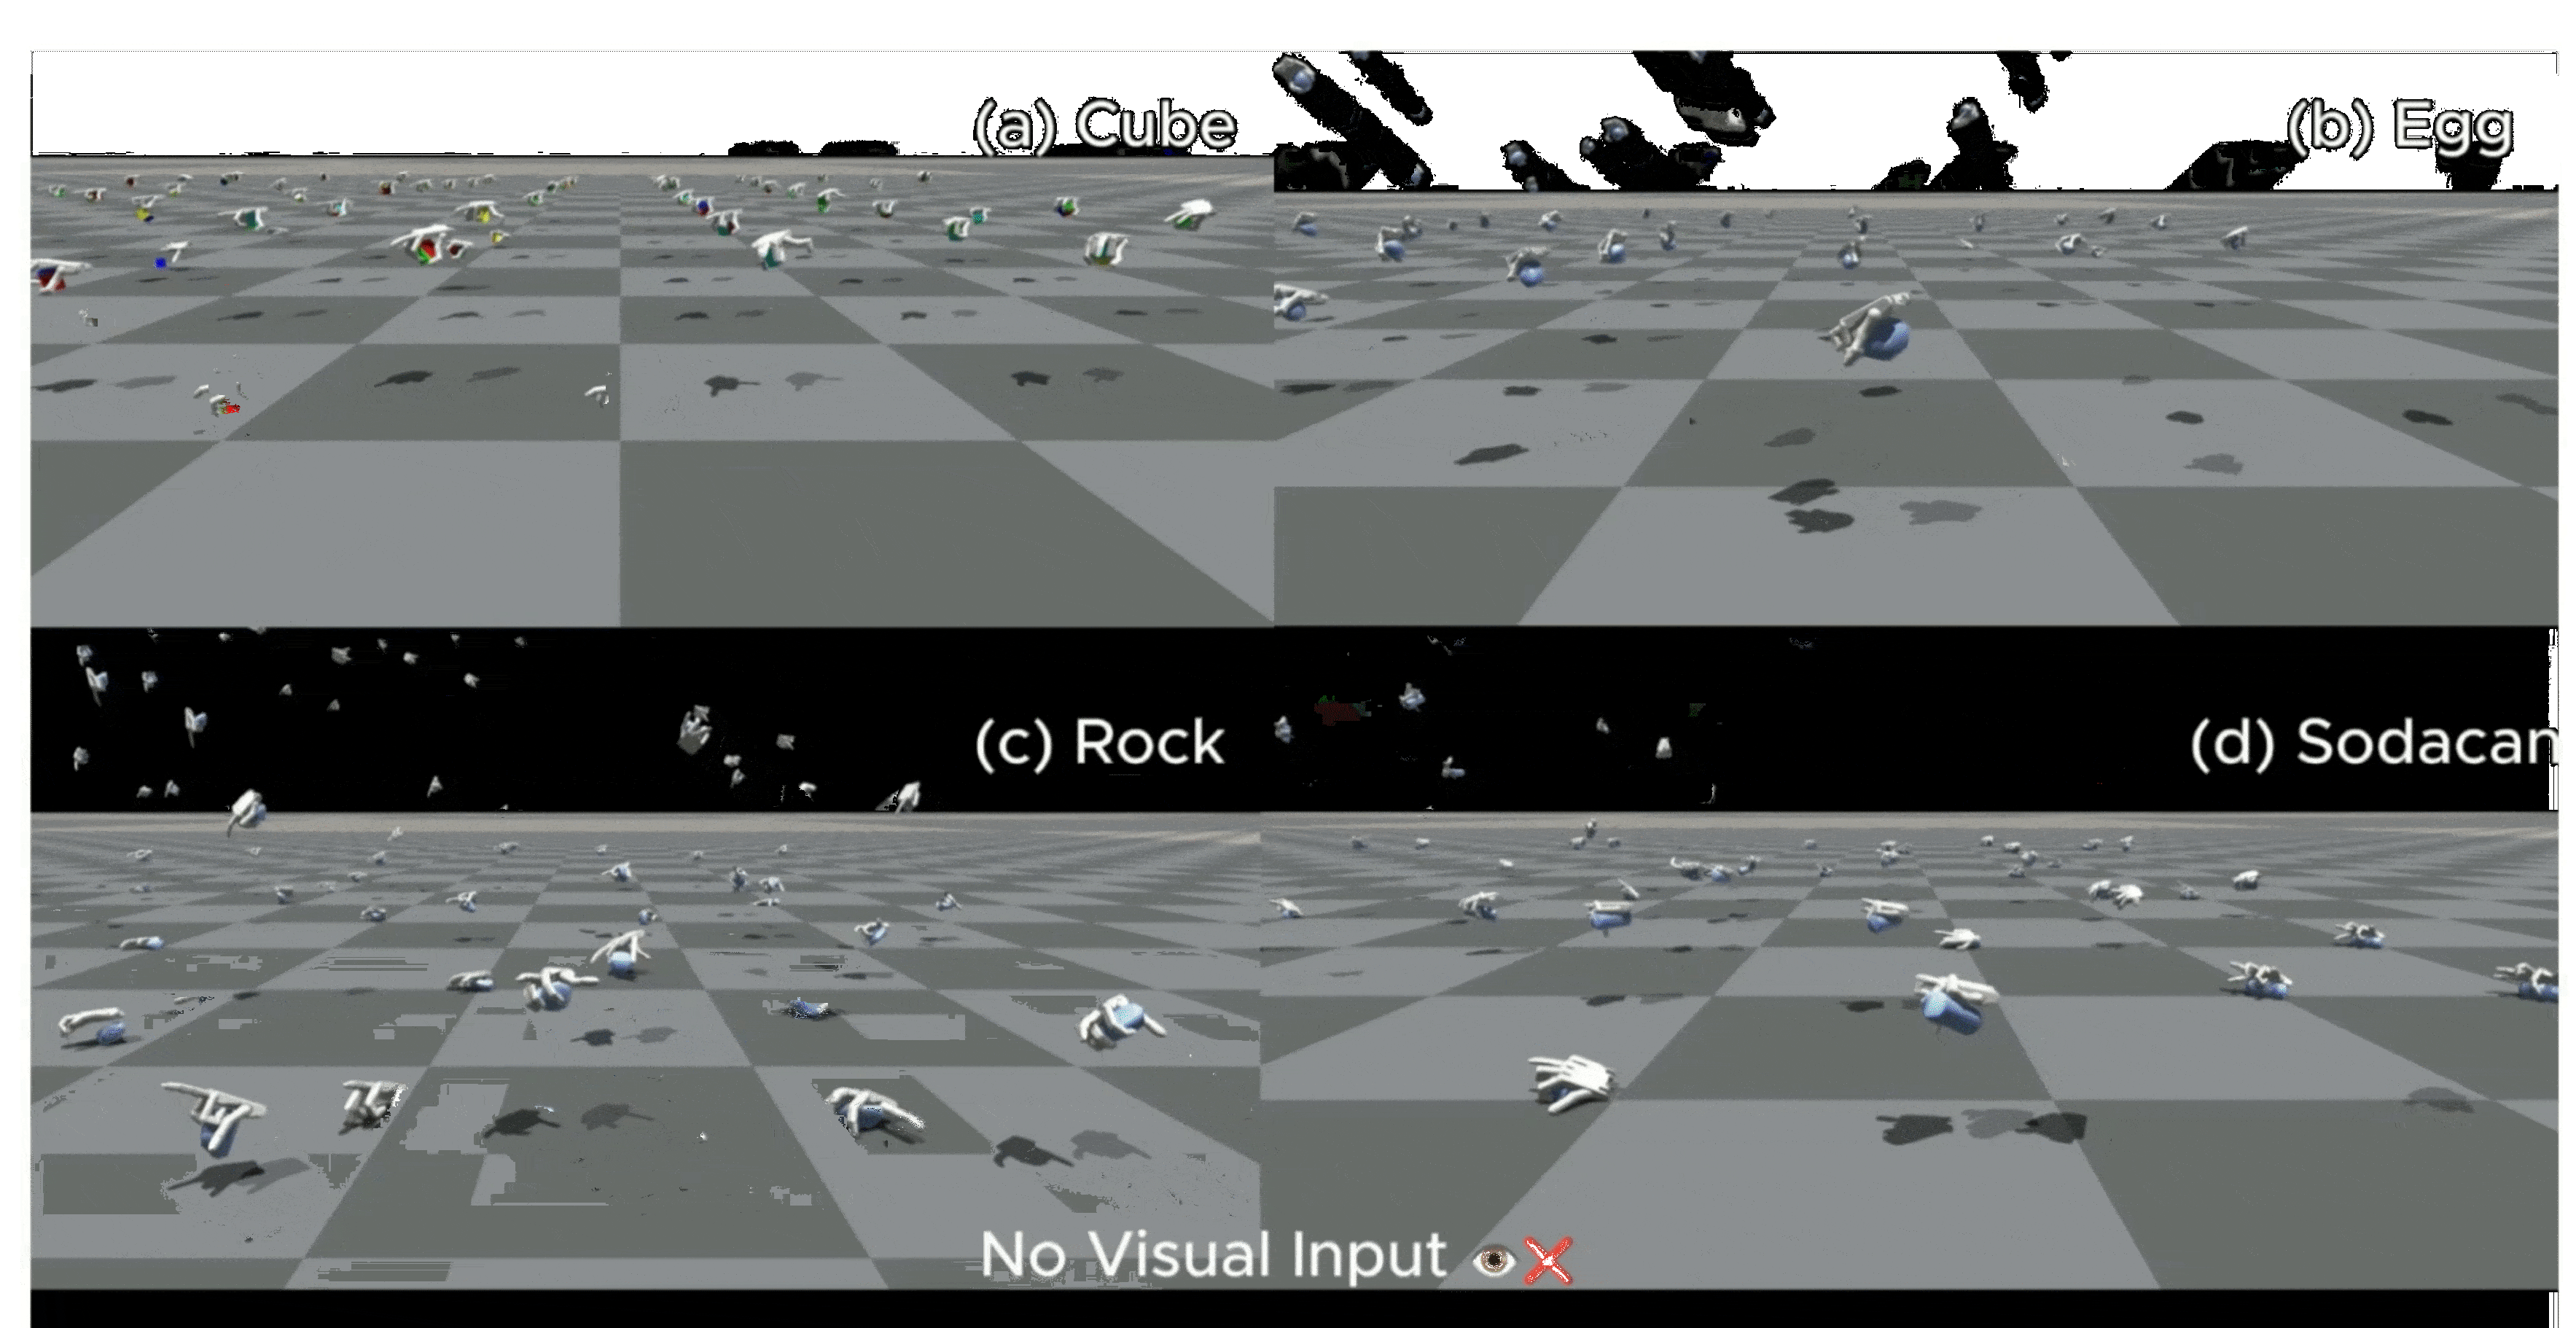
Blind Dexterous Grasping via Real2Sim2Real Tactile Policy Learning

Shengcheng Luo^, Xiyan Huang^, Zhe Xu, Wanlin Li*, Ziyuan Jiao*, Chenxi Xiao*
^ Equal contribution.
Under Review
PDF Webpage Code

ETac project thumbnail

ETac: A Lightweight and Efficient Tactile Simulation Framework for Learning Dexterous Manipulation

Zhe Xu, Feiyu Zhao, Xiyan Huang, Chenxi Xiao*
2026 IEEE International Conference on Robotics & Automation (ICRA)
🏆 ICRA 2026 Best Student Paper
PDF Webpage Code

TwinTac project thumbnail

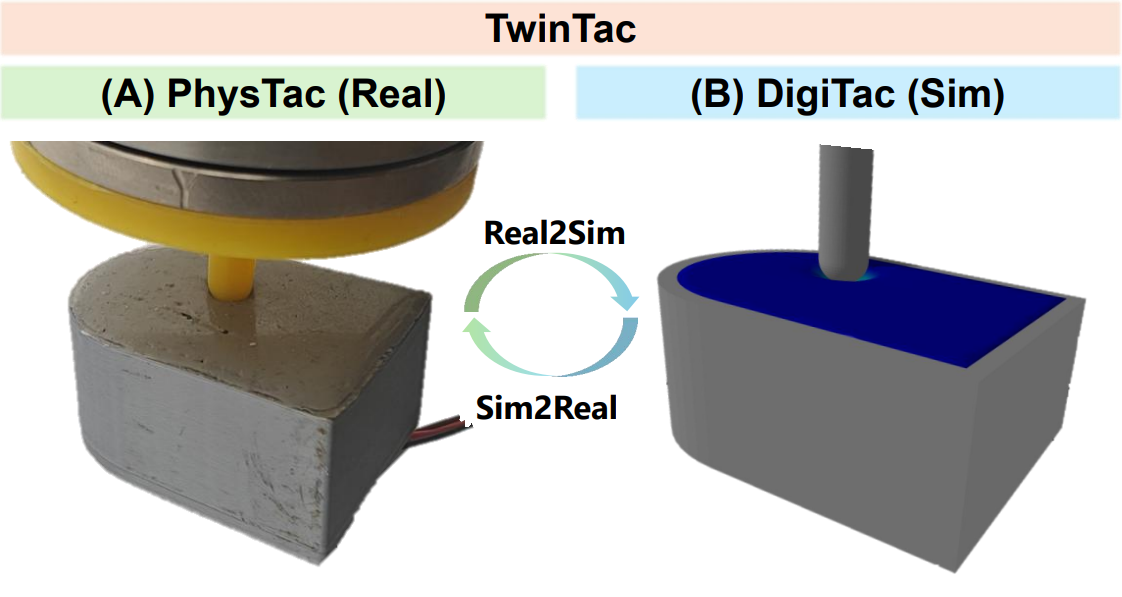
TwinTac: A Wide-Range, Highly Sensitive Tactile Sensor with Real-to-Sim Digital Twin Sensor Model

Xiyan Huang, Zhe Xu, Chenxi Xiao*
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2025)
arXiv PDF

Conference Reviewer, ICRA 2026

Conference Reviewer, IROS 2025